Prototype in developmentPrototipo in sviluppo
Orbinel · first robotOrbinel · primo robot

Kheiron.

A six-axis arm you can build, understand and extend. Named after the centaur who taught the heroes — because it is made to teach as much as to move.Un braccio a sei assi da costruire, capire e ampliare. Prende il nome dal centauro maestro degli eroi: è fatto per insegnare tanto quanto per muoversi.

Drag to rotate, scroll to zoom.Trascina per ruotare, scorri per lo zoom.

0%
SpecificationsSpecifiche

Design values.Valori di progetto.

From the CAD model and its checks. They will be confirmed — or corrected — on the printed prototype, and we will publish both.Dal modello CAD e dalle sue verifiche. Saranno confermati, o corretti, sul prototipo stampato, e pubblicheremo entrambi.

ArchitectureArchitettura6 rotary axes, anthropomorphic, spherical wrist6 assi rotoidali, antropomorfo, polso sfericoclosed-form inverse kinematicscinematica inversa in forma chiusa
Link lengthsLunghezze dei linkshoulder height 125 mm · upper arm 130 mm · forearm 130 mmaltezza spalla 125 mm · braccio 130 mm · avambraccio 130 mm
ReachSbraccioabout 400 mm from the shoulder, with grippercirca 400 mm dalla spalla, con la pinza
Joint ranges (software limits)Corse dei giunti (limiti software)J1 ±150° · J2 ±100° · J3 −120…+45° · J4 ±170° · J5 ±95° · J6 ±170°
ActuatorsAttuatori8 × Feetech STS3215 12 V serial bus servos, two on the shoulder8 × servo seriali Feetech STS3215 a 12 V, due sulla spalla12-bit magnetic encoder (0.088°), 10 kg·cm continuous, 30 kg·cm peakencoder magnetico a 12 bit (0,088°), 10 kg·cm continui, 30 kg·cm di picco
PayloadCarico utile100 g design target at full extensionobiettivo di progetto 100 g a braccio distesoestimated elbow margin 1.17 in the worst case; more in compact posesmargine stimato al gomito 1,17 nel caso peggiore; di più nelle pose raccolte
GripperPinzaparallel, rack and pinion, closed housing, 0–40 mm openingparallela, pignone e cremagliere, scatola chiusa, apertura 0–40 mm
Tool changeCambio utensilekeyed shank, two M3 locking screwscodolo con piano di orientamento, due viti M3 di blocco
ElectronicsElettronicaserial bus servo adapter + ESP32-C3 bridge inside the base, 12 V 5 A supplyadattatore per servo a bus seriale + ponte ESP32-C3 nella base, alimentatore 12 V 5 A
SafetySicurezzahardware emergency stop (NC contact): servos stop and hold position; countdown before every sequencearresto d'emergenza fisico (contatto NC): i servo si fermano e tengono la posizione; conto alla rovescia prima di ogni sequenza
Moving massMassa in movimentoabout 720 g, estimated from CAD (PETG at 55 %, servos 55 g)circa 720 g, stimata dal CAD (PETG al 55 %, servo da 55 g)
StructureStrutturafully 3D printed in PETG, about 585 g of filamenttutta stampata in PETG, circa 585 g di filamento
Expected precisionPrecisione attesaencoder resolution ≈ 0.5 mm at the tip; real repeatability depends on servo backlash, to be measuredrisoluzione dell'encoder ≈ 0,5 mm in punta; la ripetibilità reale dipende dal gioco dei servo, da misurare
SoftwareSoftwareOrbinel Motion (browser, USB via Web Serial)Orbinel Motion (browser, USB tramite Web Serial)
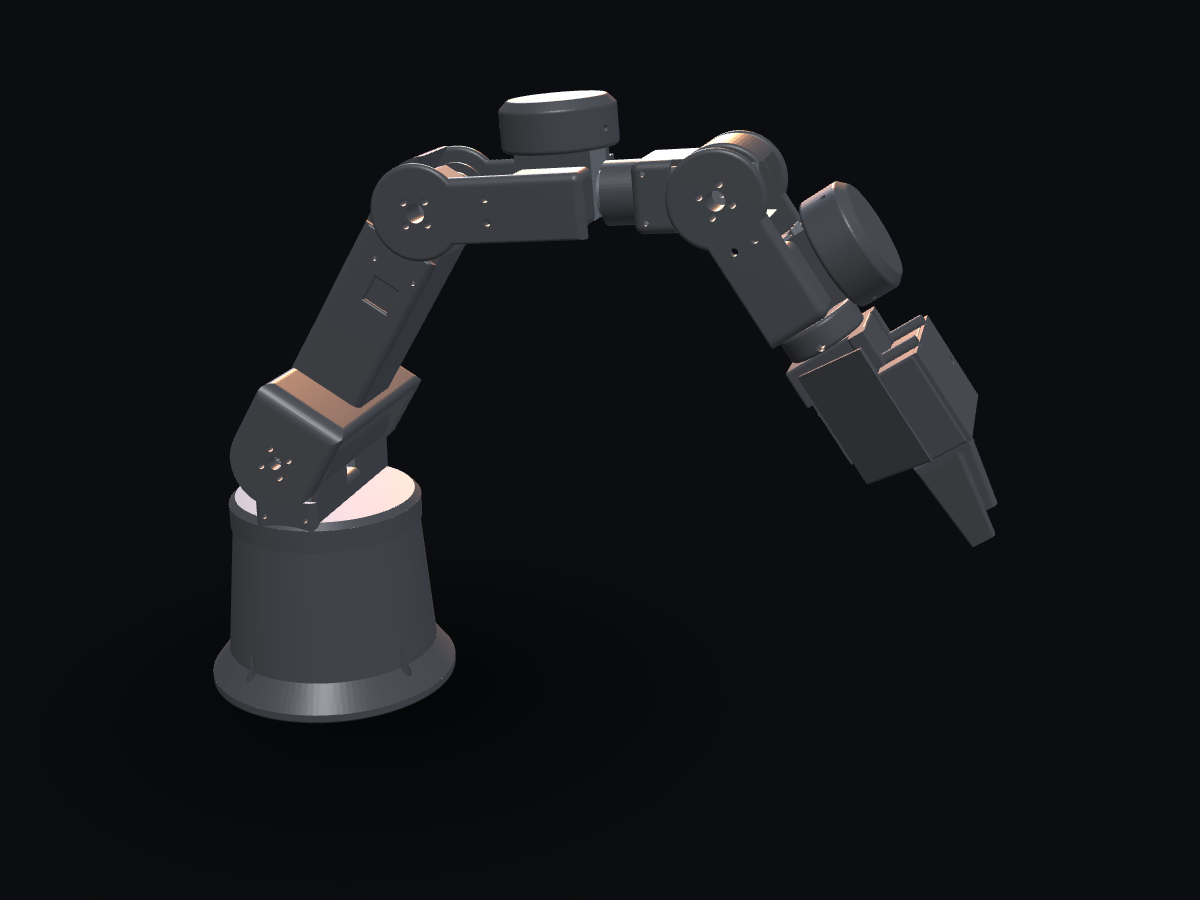
Kheiron, render
Honest statusStato reale

What is verified,
what is not yet.
Cosa è verificato,
cosa non ancora.

  • Verified in CADVerificato nel CAD — no interference at rest, single-joint ranges, gripper rack travel, torque estimates.nessuna interferenza a riposo, corse dei singoli giunti, corsa della pinza, stime di coppia.
  • Verified on hardwareVerificato sull'hardware — ESP32 bridge firmware and the emergency stop input.firmware del ponte ESP32 e ingresso dell'arresto d'emergenza.
  • Not yetNon ancora — printed parts, screw fits on the real servo, combined-pose collisions, real backlash and payload.pezzi stampati, viti sul servo reale, collisioni nelle pose combinate, gioco reale e carico utile.
Ways to get itCome averlo

Build it, kit it,
or plug it in.
Costruiscilo, montalo,
oppure accendilo.

Three tiers, released in this order. Prices will be set after the prototype is validated — join the waitlist to be first.Tre livelli, in arrivo in quest'ordine. I prezzi verranno fissati dopo la validazione del prototipo: entra in lista d'attesa per essere tra i primi.

FirstPrimo

Build Pack

DigitalDigitale
  • STL and STEP files of every partFile STL e STEP di ogni pezzo
  • Illustrated assembly guideGuida di montaggio illustrata
  • Bill of materials with where to buyDistinta dei componenti con dove comprarli
  • Print profiles and orientationsProfili e orientamenti di stampa
  • Orbinel Motion profileProfilo per Orbinel Motion
Join the waitlistLista d'attesa
ThenPoi

Kit

Printed partsParti stampate
  • All printed parts, ready to assembleTutte le parti stampate, pronte da montare
  • Everything in the Build PackTutto il Build Pack
  • Later: servos and electronics includedIn seguito: servo ed elettronica inclusi
Notify meAvvisami
LaterDopo

AssembledMontato

TestedTestato
  • Assembled, calibrated and testedMontato, calibrato e testato
  • For labs, schools and teamsPer laboratori, scuole e team
  • After safety and conformity assessmentDopo la valutazione di sicurezza e conformità
Notify meAvvisami
Dev logDiario di sviluppo

Building Kheiron.

Every step, including the ones that went wrong.Ogni passo, compresi quelli andati storti.

Orbinel Motion is bornNasce Orbinel Motion

The control panel becomes Orbinel Motion: load analysis from the CAD masses, workspace, singularities and six school lessons checked by the simulator. Bridge firmware flashed, emergency stop tested on the board.Il pannello di controllo diventa Orbinel Motion: analisi dei carichi dalle masse del CAD, spazio di lavoro, singolarità e sei lezioni per le scuole verificate dal simulatore. Firmware del ponte caricato, arresto d'emergenza provato sulla scheda.

Boards on the bench, base raisedSchede sul banco, base alzata

The ESP32-C3 works. Straight jumper wires on the UART header need 29 mm and the bay had 18.5: the shoulder goes from 110 to 125 mm above the table. The whole model turns black — one spool, one colour.L'ESP32-C3 funziona. I cavetti dritti sul connettore UART richiedono 29 mm e il vano ne aveva 18,5: la spalla passa da 110 a 125 mm dal tavolo. Tutto il modello diventa nero: una bobina, un colore.

Electronics and a real emergency stopElettronica e un vero arresto d'emergenza

An ESP32-C3 sits between computer and servos and reads a mushroom button on a normally-closed contact: pressed, every servo stops and holds. First test kit ordered.Un ESP32-C3 sta tra computer e servo e legge un pulsante a fungo su un contatto normalmente chiuso: premuto, ogni servo si ferma e tiene la posizione. Ordinato il primo kit di prova.

From boxes to a real robotDalle scatole a un robot vero

The first square version is scrapped. New joint discs, round covers and a closed parallel gripper with rack and pinion, inspired by industrial grippers. 35 of 40 random poses free of collisions; the other 5 go below the table.La prima versione squadrata viene scartata. Nuovi dischi di giunto, carter tondi e una pinza parallela chiusa a pignone e cremagliere, ispirata alle pinze industriali. 35 pose casuali su 40 senza collisioni; le altre 5 scendono sotto il tavolo.

The specificationLa specifica

Six axes, spherical wrist, smart serial servos everywhere and two on the shoulder, because one alone cannot hold the arm. The model is generated by a Python script in Fusion, so every dimension stays parametric.Sei assi, polso sferico, servo seriali intelligenti ovunque e due sulla spalla, perché uno solo non regge il braccio. Il modello è generato da uno script Python in Fusion, così ogni quota resta parametrica.